 Sandor Felber

Humanoid robots echo our own form, optimizing for the world we’ve built. Their form factor is a calculated compromise, blending adaptability, functionality, and social integration with inherent challenges in mechanical complexity and energy efficiency.
In A World Built for Humans
Let’s address the elephant in the room right off the bat: over the course of history, humanity has architected, engineered, and built an artificial functional environment around human proportions—doorways, stairs, control panels, and even everyday tools reflect our scale. Humanoid robots, crafted with dimensions, can operate within these spaces without needing costly modifications. They can climb stairs, navigate narrow corridors, reach the coffee mug in the cupboard but also the detergent under the sink, and use standard interfaces, giving them an edge over other robot types.
Replicating Human Motion
Replicating human motion isn’t simple. To approach the range of movement of the 600+ muscles of humans, humanoid robots require numerous joints and actuators, which increases complexity and volume-/power-to-weight ratio requirements for these components compared to their wheeled counterparts.
Balancing on two legs is inherently less stable than on three or four, but it is a challenge of control system development rather than a pure physical limitation. From a first principles perspective, a one-legged design lacks sufficient support for dynamic balance, especially when it comes to climbing obstacles. Conversely, using more than two legs increases mechanical complexity, power demand, and weight, rendering the design less agile. Coordinating complex movements with two legs, and reacting to accidental collisions with the environment push our current control algorithms and AI capabilities to their limits but as those limits are expanding and we are discovering how to squeeze more out of our neural networks of a certain parameter size, we can address these problems with increasing stability and robustness.
Similarly, as it happens, two arms are not just to copy how humans look, but because they provide the capabilities required for meaningful manipulation and interaction. A single arm would limit versatility, payload, and require constant repositioning (or a custom end effector to manipulate the target object, like Stretch), while more than two arms add unnecessary weight and complexity without significant benefits for most human-scale tasks. Two arms offer sufficient dexterity for tasks like grasping larger objects, tool use, and object manipulation while maintaining a balance between capability and mechanical simplicity.
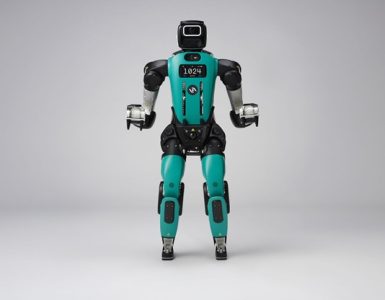
An interesting side note here is that ostriches are capable of storing lots of elastic energy in their tendons as they run which enables them to use half as much energy as we do at our top running speed. Why not ostriches then? Digit is an example of an ostrich-inspired design, but this is a compromise between the efficiency of locomotion on close-to-flat terrains and whole-body interaction and manipulation-related tasks such as climbing on the countertop to reach that forgotten jar at the back of the very top shelf of your kitchen.
The MIT Biomimetic Lab’s cheetah-inspired work shows that an active tail can reject disturbances and improve turning agility. However, adding a tail increases weight and control complexity, so its benefits depend heavily on the specific task and platform design.
Optimality in Imperfection
This is not to say that the humanoid is the perfect or most efficient form factor for every application but rather that it is the most general-purpose form factor. I mean this in the sense that given any realistic unknown task, it has the highest probability of being able to successfully perform that task autonomously without running into some unseen limitation due to its form factor. Their human-like design means they can work with existing tools, interfaces, and vehicles. This compatibility significantly cuts down integration and development costs. Humanoid robots replicate human gestures and expressions, making social and collaborative tasks more natural. This ease of interaction is crucial in service and assistive roles.
Yes, dog-like quadruped robots equipped with arms tend to offer robust solutions for tasks that require interaction below ~1 ft, anything above that can be troublesome to keep in the field of view of the quadruped’s perception system (or its arm reach) as it’s manipulating the object. Yes, drones offer the quickest 3D mobility and access to hard-to-reach areas. But their payload and runtime are limiting factors alongside the lack of dexterity needed for precise manipulation and social interaction. And yes, dual-armed wheeled robots like Reflex tend to be way more efficient on a clean factory floor where the floor is perfectly flat and there are no obstacles, rubber debris, wires, or anything that has a decent chance of getting a wheel and hence the robot stuck.
From a Robot Learning Perspective
Leveraging Human Data
Humanoid robots mirror human joint configurations and limb movements, allowing researchers to harness vast troves of existing human motion data. Extensive motion capture databases from sports science, healthcare, rehabilitation, and other fields offer ready-made datasets for training learned whole-body controllers. Imitation learning becomes more straightforward and intuitive when a robot’s kinematics closely match human patterns, making it easy to collect further demonstrations of how to perform certain tasks in the real world like swapping the AAA batteries in your remote control and performance benchmarking is also easier.
Natural Biomechanics
Human movement is inherently energy-efficient and robust, thanks to millions of years of evolution. Humanoid robots can embed these biomechanical principles into their control systems. Reinforcement learning policies can learn to exploit the dynamics of any form factor, for humanoids for example this means an optimized efficiency for the pendulum-like gait swing during walking and any elasticity of the legs if modeled.
TLDR;
Humanoid robots make sense because they’re designed to thrive in a world tailored for humans. Their human-like form enables them to use existing infrastructure and interact naturally with people. Despite the challenges of increased mechanical complexity, energy inefficiency, and sophisticated control requirements, the benefits are compelling—especially in environments where social interaction and adaptability are key. From a robot learning and reinforcement learning perspective, leveraging human motion data and capitalizing on natural biomechanics are also significant advantages. These factors combine to make humanoid robots not just a novelty, but a practical, robust solution for integrating robotic technology into our human world.

 Humanoid Robotics Technology