 Humanoid Robotics Technology

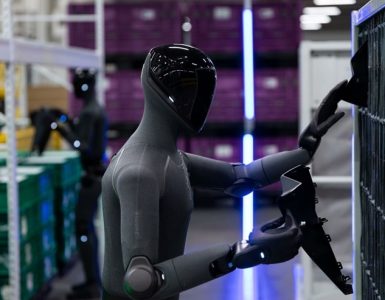
Figure shares the results of an 11-month Figure 02 robot deployment at BMW Group Plant Spartanburg. Within 6 months of bringing up Figure 02, they delivered robots to the plant and began testing. Within 10 months, they launched full deployment on an active assembly line at the plant, running every single working day.
BMW Deployment Highlights:
- Ran 10-hour shift Monday-Friday
- 90,000+ parts loaded
- 1,250+ hours of runtime
- Contributed to the production of 30,000+ X3 vehicles
- Estimated 1.2+ million robot steps or 200+ miles
Following the release of Figure 03, they are officially starting the retirement of Figure 02, their second-generation humanoid robot. With Figure 02’s return to HQ from BMW as part of their fleet-wide retirement, Figure would like to highlight key learnings that can be rolled into Figure 03 operational readiness.
Deployment Overview
Figure’s first use case with BMW was sheet-metal loading, a classic pick-and-place task in automotive manufacturing. An associate picks sheet-metal parts from racks or bins and places them on a welding fixture, after which six-axis industrial robots weld and feed the parts into the main line.
To measure robot progress, they defined three critical KPIs:
- Cycle time: Total time to complete one cycle, including the loading phase after the weld-fixture door opens. The requirement was 84 seconds total, 37 seconds load time.
- Placement accuracy: Percentage of cycles where all three sheet-metal parts are correctly loaded. Their target was > 99% success per shift.
- Interventions: Number of times a human must pause or reset the robot. The goal was zero per shift.
The challenge of this use case is in balancing speed and precision – placing parts within a 5-millimeter tolerance in just 2 seconds.
To meet this, Figure’s robots had to achieve precise yet adaptive locomotion, allowing rapid, accurate foot placement and real-time responsiveness to environmental changes. Figure also developed advanced hand-eye coordination algorithms and built field-calibration tools for consistent cross-robot performance.
Hardware Reliability and Learnings
Six months of daily runtime yielded invaluable insights for Figure’s mechanical and reliability teams. Across 1,250+ operational hours, Figure 02 recorded minimal hardware failures while generating critical data that informed the build procedures, component architecture, and mechanical design of Figure 03.
One learning that informed Figure 03’s design was the robot’s forearm, its top hardware failure point at BMW. The forearm is a challenging subsystem due to its tight packaging, dexterity requirements (three degrees of freedom), and thermal constraints. Figure 02’s forearm contained a microcontroller-based PCB that distributed communications between the main computer and the wrist actuators.
For Figure 03, they completely re-architected the wrist electronics to eliminate both the distribution board and dynamic cabling. Each wrist’s motor controller now communicates directly with the main computer, reducing complexity, improving reliability, and simplifying thermal management.
Source: Figure